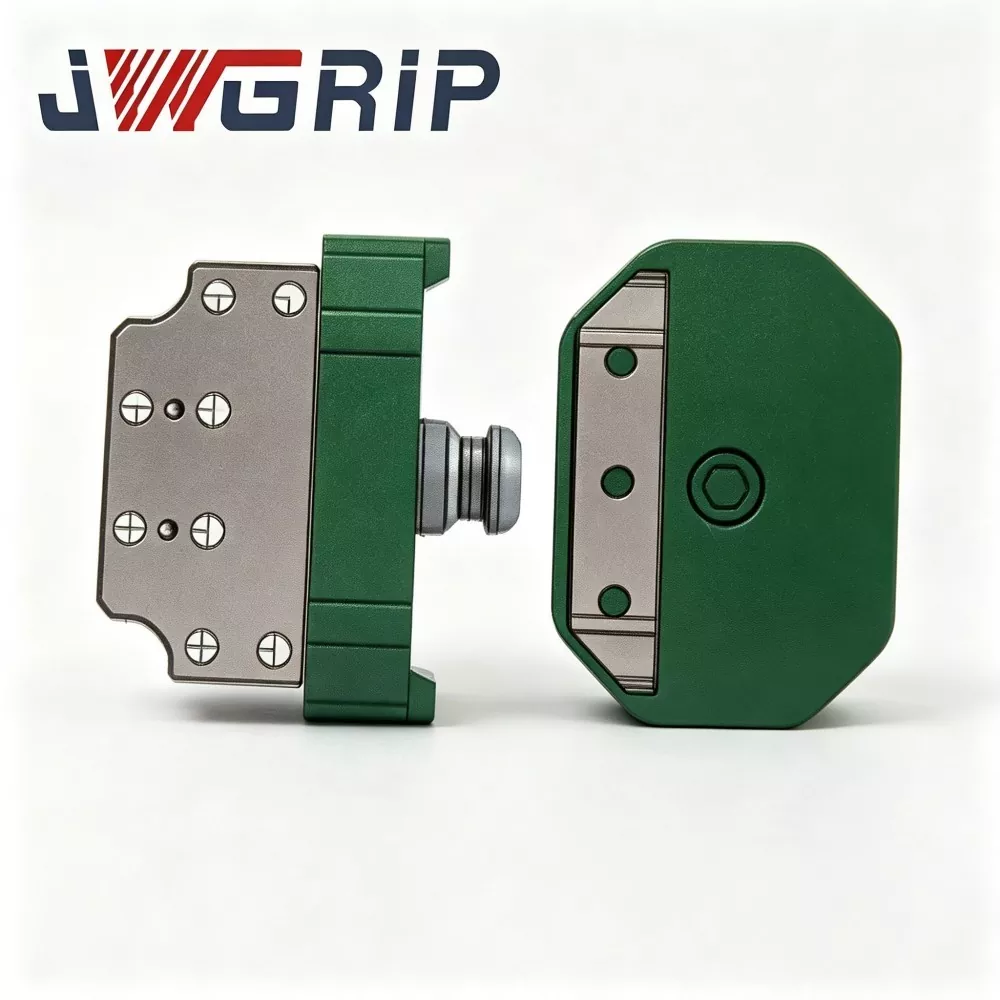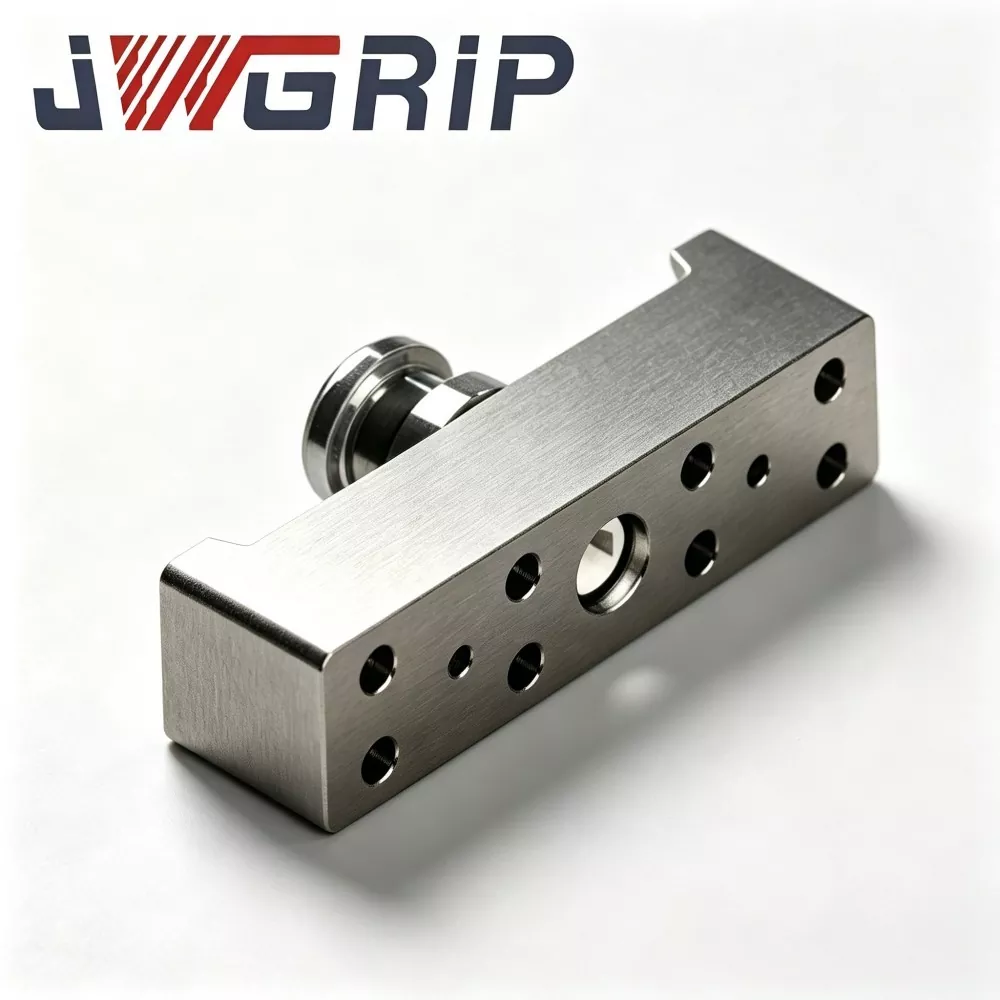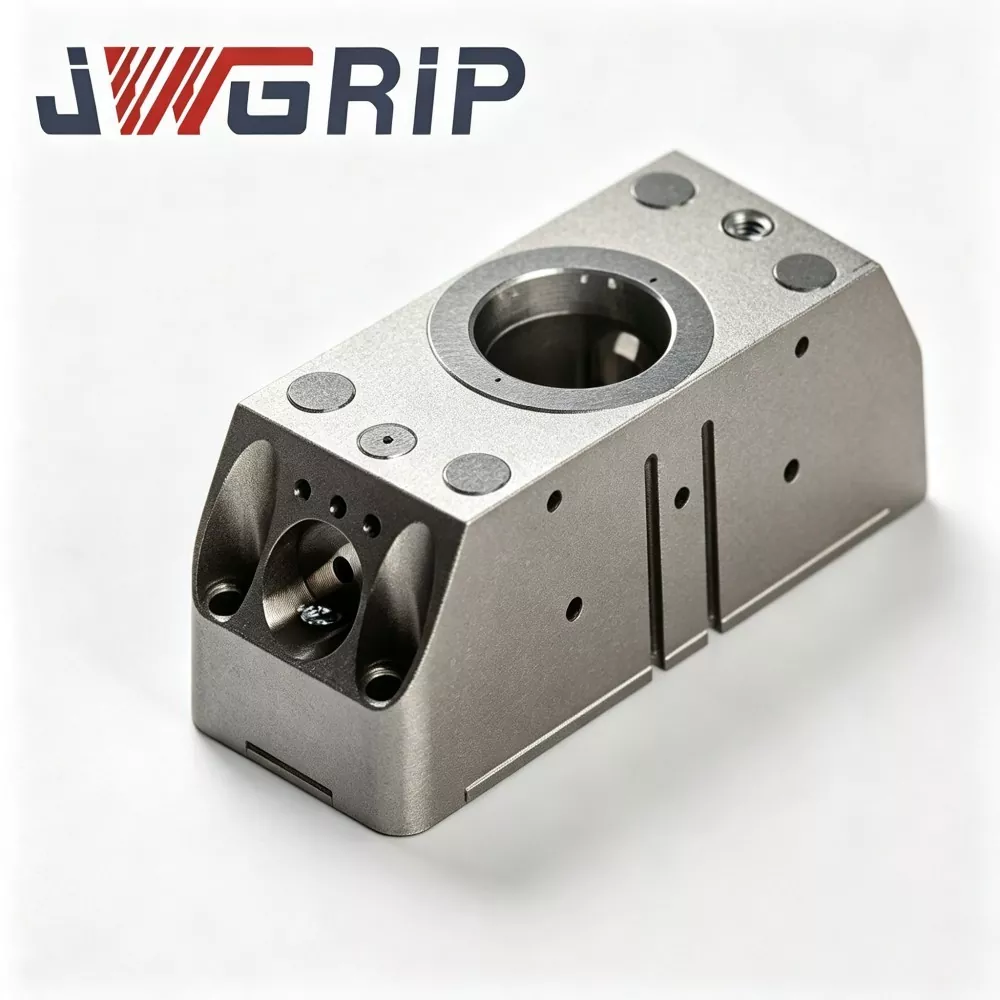
N160 Robot Quick Change Gripper Module
JWGRIP is the professional manufacturer and supplier of N160 Robot Quick Change Gripper Module in China, supporting Bulk Order procurement and providing genuine Factory Price for global automation project partners. It is a newly upgraded integrated robot end-of-arm execution unit specially designed for modern flexible unmanned production lines. Innovatively integrating pneumatic parallel gripper and robot quick-change interface into a single modular body, it eliminates the need for separate quick-change discs and independent gripper assembly, requiring no additional multi-layer connecting flanges or transitional accessories.
This high-performance N160 Robot Quick Change Gripper Module adopts high-strength aviation aluminum alloy housing and quenched alloy steel locking core, featuring outstanding durability and stable mechanical performance. Abandoning the traditional split combined structure, it effectively reduces cumulative positioning errors caused by multi-layer connection and on-site assembly deviation. The module has passed millions of cyclic fatigue tests and fully complies with CE mechanical safety standards, maintaining long-term stable operation in high-frequency cyclic grabbing and switching scenarios.
Finished with full in-house manufacturing procedures including raw material inspection, CNC precision machining, vacuum heat treatment, surface hardening and full-load cyclic verification, each unit delivers consistent high-quality performance. It is widely applicable for new energy component assembly, automotive small parts handling, 3C precision workpiece grabbing and household appliance component sorting. Supporting single-unit trial purchase and large-batch order cooperation, it is equipped with complete 2D/3D drawing data, installation guidance and remote technical support, greatly reducing on-site assembly and calibration workload and shortening the renovation cycle of intelligent flexible production lines for discrete manufacturing enterprises.
Integrated Module Design Rationale
With manufacturing shifting toward multi-variety and small-batch production mode, more automated production lines demand one single industrial robot to complete multiple grabbing tasks.
Traditionally, system integrators purchase quick-change disc and pneumatic gripper separately, assemble them together on robot flange during field commissioning.
This solution brings many hidden troubles:
1. Multiple mating flanges stack dimensional tolerances, degrading overall repeat-positioning accuracy.
2. Exposed external air tubes suffer friction damage during frequent tool-change cycles.
3. A large amount of working hours are consumed for on-site assembling and calibration.
N160 Robot Quick-Change Gripper Module is developed to solve above-mentioned practical pain-points. JWGRIP integrates quick-change locking mechanism, gas circuit channel and parallel gripping jaws into one compact module unit.
The whole set is divided into:
① Robot-side base (permanently mounted on robot flange)
② Interchangeable tool-side gripper module
After one-time installation of robot-side base on robot flange, robot can finish automatic tool swap by docking different tool-side modules without repeated disassembly of flanges on site.
Standard N160 Robot Quick Change Gripper Module in stock covers multiple gripping-force grades, which can match most mainstream six-axis industrial robots and collaborative robots. For special-condition projects, customized and OEM services can be activated. Whether small-batch trial purchase or bulk order, customers can get factory-price support from our factory direct supply channel.
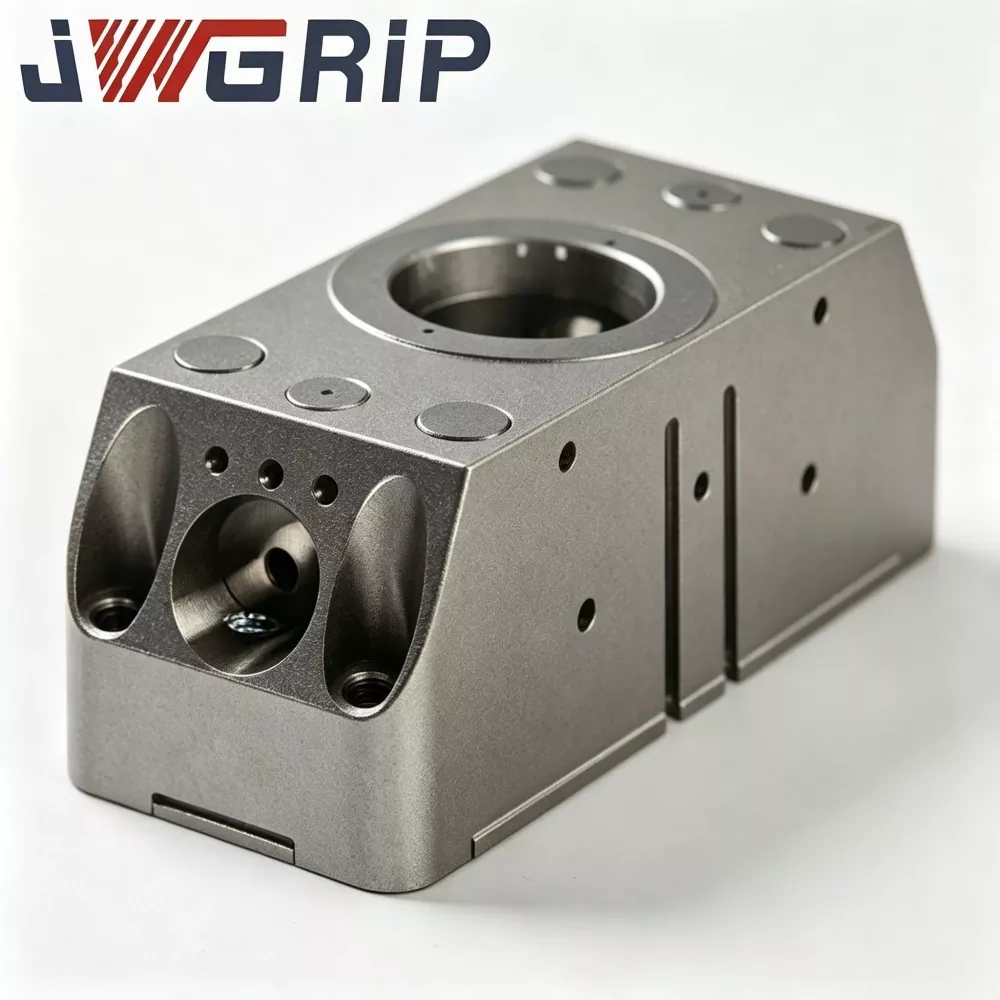
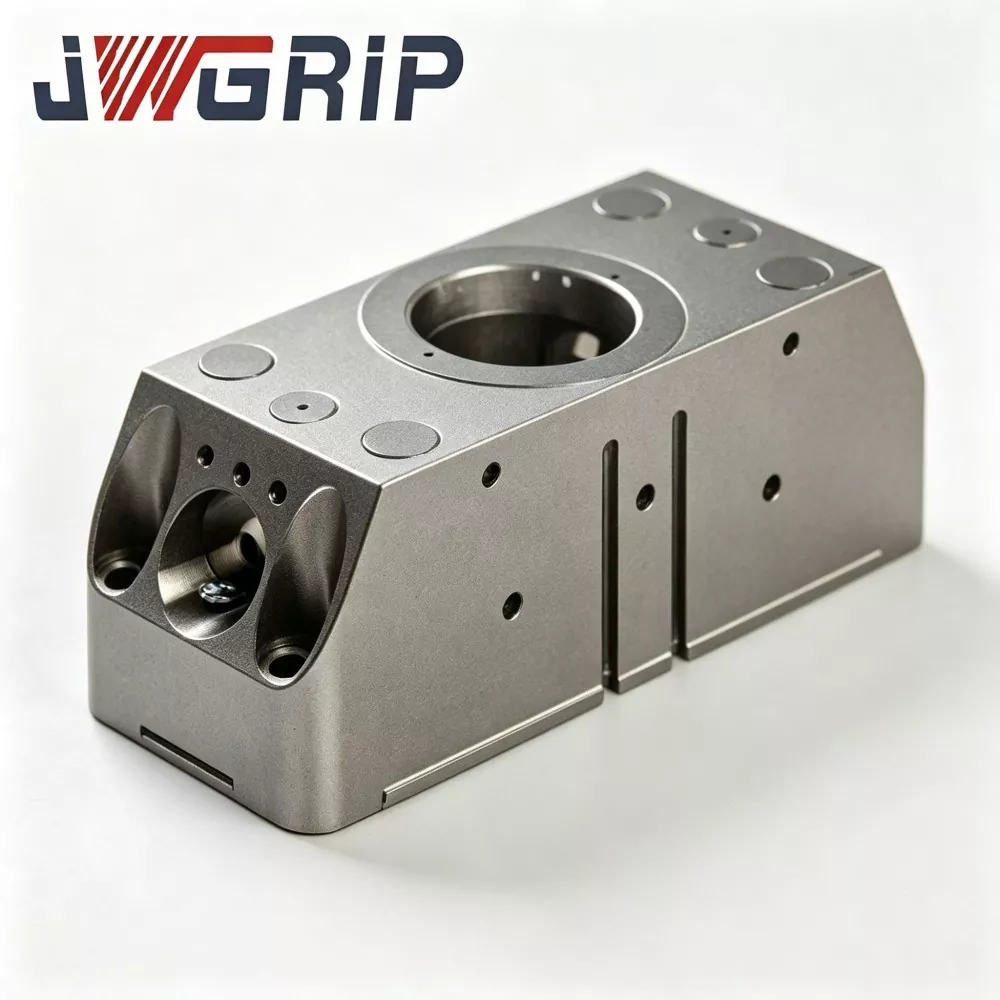
Product Definition & Core Composition
N160 Robot Quick-Change Gripper Module is an integrated robot end-effector that organically combines robot quick-change interface and parallel pneumatic gripper. Unlike discrete components that need secondary assembling at customer site, each N160 Robot Quick-Change Gripper Module finishes assembling, air-circuit debugging and cyclic performance test inside JWGRIP factory before delivery.
Core composition breakdown:
1. Robot-side master base&Permanently fixed to robot output flange. It contains: - Pneumatic inlet channel - Mechanical locking driving assembly - Built-in status feedback sensor
This component stays mounted on robot arm without frequent disassembly.
2. Tool-side slave gripper module Interchangeable working unit, including: - Alloy locking mating gear - High-precision locating pin holes - Built-in internal gas passages - Parallel gripping jaws
Multiple sets of tool-side modules with different jaw profiles, gripping force and stroke can be prepared for different workpieces.
Working flow:
When robot moves to tool-rest station, compressed air drives mechanical locking gear inside robot-side base to engage with tool-side gear set. - High-precision locating pins realize high-accuracy positioning - Internal gas passages complete pneumatic connection for gripper driving - Sensor feeds locking-unlocking real-time signal back to robot controller to realize safety interlock control
Many N160 Robot Quick-Change Gripper Module manufacturers only supply separated spare-parts, leaving assembling and tolerance-control work for integrators. Our integrated design transfers most assembly-related risks to in-factory production links, lowering uncertainty for end-user projects.
Core Performance & Structural Features
1. Integrated modular structure to minimize tolerance stack-up
Advanced N160 Robot Quick-Change Gripper Module cancels intermediate transition flange between quick-change disc and gripper. Key matching surfaces are processed and calibrated inside factory. The repeat positioning accuracy after docking can reach ≤±0.010 mm, ensuring stable grabbing precision for high-precision assembling scenes.
2. Built-in mechanical self-locking & electrical signal interlock
Comply with CE mechanical safety requirement. Even if compressed-air source is cut off accidentally in operation process, mechanical locking teeth still keep meshing state to prevent tool-side module dropping. Robot can execute movement instruction only after receiving "fully locked" feedback signal from sensor, realizing safety protection for unmanned workshops.
3. Embedded internal gas-circuit layout
Gas channels are embedded in module housing instead of external exposed tubing. - Reduces pipeline abrasion risk caused by frequent tool-change movement - Lowers failure probability of air leakage and joint loosening in long-term cyclic production
4. Easy-maintainable modular wearing-part design
Key consumable components including sealing rings, guiding sliding blocks and locating-pin sleeves adopt independent modular design. When doing regular maintenance, users only replace local wearing-parts without detaching whole module from robot flange. It shortens equipment maintenance downtime.
5. Wide-range compatibility & flexible custom support
Standard N160 Robot Quick Change Gripper Module in stock adapts to most mainstream industrial robots and collaborative robots. When facing special jaw shape, ultra-large stroke, special mounting hole layout or anti-corrosion requirement, customized and OEM service can be realized.
6. Strict factory pre-delivery verification
As professional N160 Robot Quick-Change Gripper Module supplier, every finished product must go through: Gripping-force detection , Air-tightness inspection ,Thousands-time locking-unlocking and gripper opening-closing cyclic test
Quality Verification
1. Raw-material incoming inspection
Chemical composition and hardness test for aluminum-alloy and alloy-steel raw bars; reject unqualified raw-material.
2. CNC rough-machining & finish-machining
Process housing, locking gear, jaw base and locating components. Strict dimension tolerance control.
3. Vacuum heat-treatment & surface treatment
Quench and temper alloy-steel locking core and locating pin for higher hardness and wear-resistance; hard-anodize aluminum-alloy housing.
4. Precision grinding
For key datum surfaces and pin holes, guarantee surface roughness and dimensional tolerance.
5. Assembly procedure
Assemble locking assembly, sliding guide parts, sealing rings and built-in sensor, complete internal gas-circuit layout.
6. Semi-finished product pre-test
Air-tightness inspection, gripping-force calibration, action debugging and signal-feedback verification.
7. Cyclic load fatigue test
Every finished N160 Robot Quick-Change Gripper Module runs thousands of locking-unlocking and gripper opening-closing cycles under simulated working load. Fail products will be reworked.
8. Final inspection, serial-number marking and warehousing
Qualified products become N160 Robot Quick-Change Gripper Module in stock.
Multi-industry Application Scenarios
1. New-energy component assembly
Battery-cell stacking, module handling, connector assembly. Integrated module design avoids tolerance stack-up, ensuring precise grabbing position for high-value new-energy components.
2. Automotive small-parts handling
Engine small components, fasteners, plastic interior parts. Fast automatic tool-swap supports mixed-batch automotive assembly lines.
3. 3C precision workpiece grabbing
Mobile-phone components, notebook shells, electronic connectors. ≤±0.010 mm repeat-positioning accuracy satisfies high-precision 3C assembly requirements.
4. Household-appliance component sorting
Plastic shells, metal brackets, motor components. Multiple tool-side modules with different jaw profiles adapt to varied household-appliance part geometries.
5. General flexible automation stations
Multi-variety small-batch production lines requiring one robot to handle multiple part types. Pre-assembled integrated module greatly shortens station-commissioning cycle.
Installation & Commissioning Key Points
1. Mount robot-side master base onto robot flange; tighten mounting bolts strictly following torque-values stated in official documentation. Avoid over-torque fastening which may cause base-body micro-deformation.
2. Prepare tool-rest station for placing idle tool-side gripper modules. Guarantee tool-rest positioning accuracy to support stable automatic docking.
3. Complete pneumatic-circuit connection for robot-side base; install air-filter pressure-regulator unit at front-end of compressed-air inlet. Stabilize working air-pressure within 0.5-0.7 MPa.
4. Connect sensor-signal cable to robot-PLC IO-port; verify lock-status-feedback-signal logic; configure robot motion-interlock logic: robot shall not perform high-speed movement unless "fully-locked" signal is received.
5. Execute manual jog-mode docking-simulation first before automatic-cycle production. Check docking smoothness, air-tightness and signal-feedback correctness. Eliminate mechanical-interference risks.
6. Compile robot-program tool-change sub-routines; define safe approaching distance and docking-speed parameters. Avoid high-speed hard-collision between master-base and slave-module.
Procurement & Project Evaluation
Core value of JWGRIP N160 Robot Quick Change Gripper Module:
① Integrated one-body design merging quick-change interface and parallel gripper, eliminating intermediate flange tolerance stack-up
② ≤±0.010 mm repeat-positioning accuracy
③ Mechanical self-locking + electrical signal dual-safety mechanism, CE-compliant
④ Embedded internal gas-circuit layout, avoiding external tube abrasion
⑤ Modular replaceable wearing-parts, low maintenance cost
⑥ Multi-gripping-force-grade product matrix, compatible with mainstream industrial and collaborative robots
⑦ In-house full-process manufacturing, strict pre-delivery cyclic verification
It solves key automation-station bottlenecks:
Cumulative tolerance from split quick-change disc + gripper assembly
Long on-site assembling and calibration time
External air-tube abrasion and air-leakage failure
Safety risk of tool dropping under air-supply loss
High maintenance cost from non-modular wearing-parts
Project-evaluation reminders:
1. Confirm actual robot-flange dimension and required rated-load (consider dynamic impact-load, not merely static weight of gripper + workpiece). Reserve adequate safety-margin.
2. Clarify gripping-force grade, jaw opening stroke and jaw profile requirements for target workpieces.
3. Verify workshop compressed-air-source quality and pressure-stability; recommend air-filter pressure-regulator combination if pressure fluctuates severely.
4. Confirm robot-PLC IO-resource condition for lock-status-signal reception. JWGRIP provides free electrical-interface-documentation.
5. Standard stocked versions realize fast delivery; adopt customized / OEM service for special-flange, special-sealing-grade (IP upgrade), special jaw-profile or ultra-large-stroke requirements.
FAQ
Q1: Can N160 Robot Quick-Change Gripper Module realize fully-automatic tool-swap without manual bolt disassembly?
Yes. N160 Robot Quick Change Gripper Module responds to pneumatic control signal from robot system and completes locking-unlocking automatically. Tool-swap logic can be integrated into robot program. Tool-storage rack for placing idle tool-side modules needs to be prepared on-site.
Q2: Do I need large-scale coordinate re-calibration every time swapping tool-side modules?
Under correct installation condition, repeat positioning accuracy ≤±0.010 mm. Large-scale re-calibration is unnecessary; minor fine-tuning can be finished during initial commissioning.
Q3: My robot flange is non-standard, can I adopt N160 Robot Quick-Change Gripper Module?
N160 Robot Quick-Change Gripper Module in-stock models fit mainstream robot flanges. For non-standard interface, customized and OEM service can modify mounting flange according to customer drawings.
Q4: What happens if air supply cuts off accidentally in robot movement?
Mechanical self-locking structure is built-in. Even compressed-air disappears, locking teeth keep meshing to prevent tool-side module dropping. Unlocking action can only be triggered when unlocking signal and valid air pressure exist simultaneously.
Q5: What maintenance cycle should I follow for N160 Robot Quick-Change Gripper Module?
Under 24-hour continuous production, inspect consumable parts every 250 000 cycles, clean datum surface and add anti-wear grease. Shorten maintenance interval for heavy-dust workshop.
Q6: Can N160 Robot Quick-Change Gripper Module work under splash-prone workshop?
Standard version reaches IP53 grade, fit for ordinary workshop. For splash-prone, high-humidity and slightly corrosive environment, select customized N160 Robot Quick-Change Gripper Module with upgraded sealing and anti-corrosion treatment.
Hot Tags: N160 Robot Quick Change Gripper Module Manufacturer, Supplier, Factory
Send Inquiry
Contact Info
-
Address
No. 44, Daning Entrepreneurship Road, Humen Town, Dongguan City, Guangdong Province, China
-
Tel
-
Email
Welcome to send inquiry to JWGRIP. Our professional technical and sales team will provide free fixture selection, customized solution design and accurate quotation.